MATCH 07
Southwest University · RoboMaster
Start here
become a young engineer
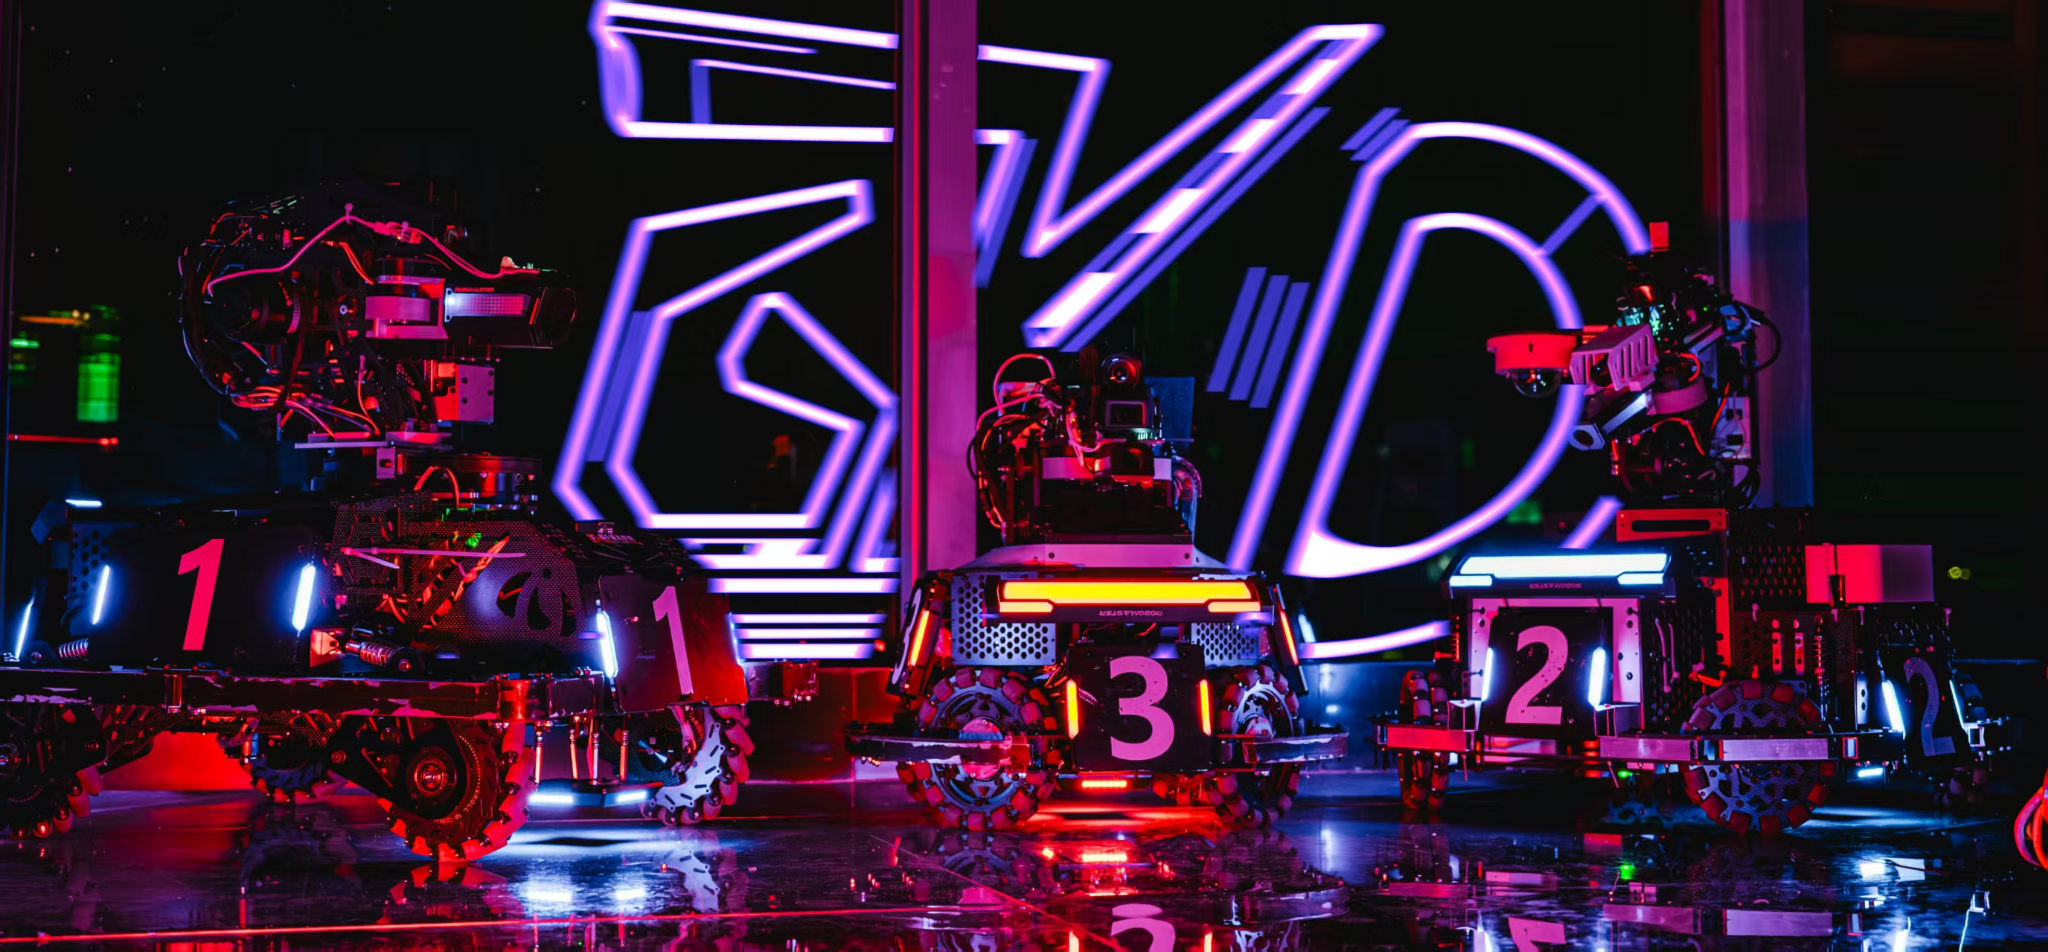
Welcome to GKD
Working from real competition requirements, we independently handle mechanical design, hardware development, control systems, vision and algorithms — then iterate through testing and full-robot integration until every design becomes a robot that runs reliably and actually competes.
At GKD we care most about turning ideas into reliable engineering. From concept to machined parts, from a single module to the whole robot, every iteration asks you to find problems, test solutions and improve them. Through RoboMaster we want members to build real engineering judgement, hands-on skill and teamwork — and to carry that into whatever they explore next.
GKD / 2026 CHONGQING
Selected matches
Scroll sideways · ordered by match
MATCH 31
Hunan University of Science and Technology Dust vs Southwest University GKD
Watch on Bilibili ↗MATCH 47
Southwest University GKD vs National University of Singapore Calibur
Watch on Bilibili ↗MATCH 56
Guilin University of Electronic Technology (Beihai) PoLangDuXing vs Southwest University GKD
Watch on Bilibili ↗MATCH 60
Xi'an Jiaotong University Duxing vs Southwest University GKD
Watch on Bilibili ↗Five groups, one robot
98% give up here. 100% grow here
Control
Chassis and gimbal control, state machines and communication. Beyond writing C++, you tune your code against real motors and sensors.
Control learning path →Vision
Armour-plate detection, target tracking and motion prediction — turning what the camera sees into target data the control group can use, while dealing with latency and false positives.
Vision learning path →Hardware
Main controllers, motor drivers, power and communication boards — making sure the schematic is correct, the PCB can be manufactured and the board survives real operation.
Hardware learning path →Mechanical
Robot structure, transmission and final assembly, satisfying size, strength, manufacturability, serviceability and referee-system mounting all at once.
Mechanical learning path →Navigation
Serves the sentry — the only robot on the field with no operator. It must decide where to go and how to get there by itself, so this group handles localisation, mapping, destination decisions and path planning, handing the result to the control group to execute.
Navigation learning path →